Skye/Luna Product Overview
Product positioning
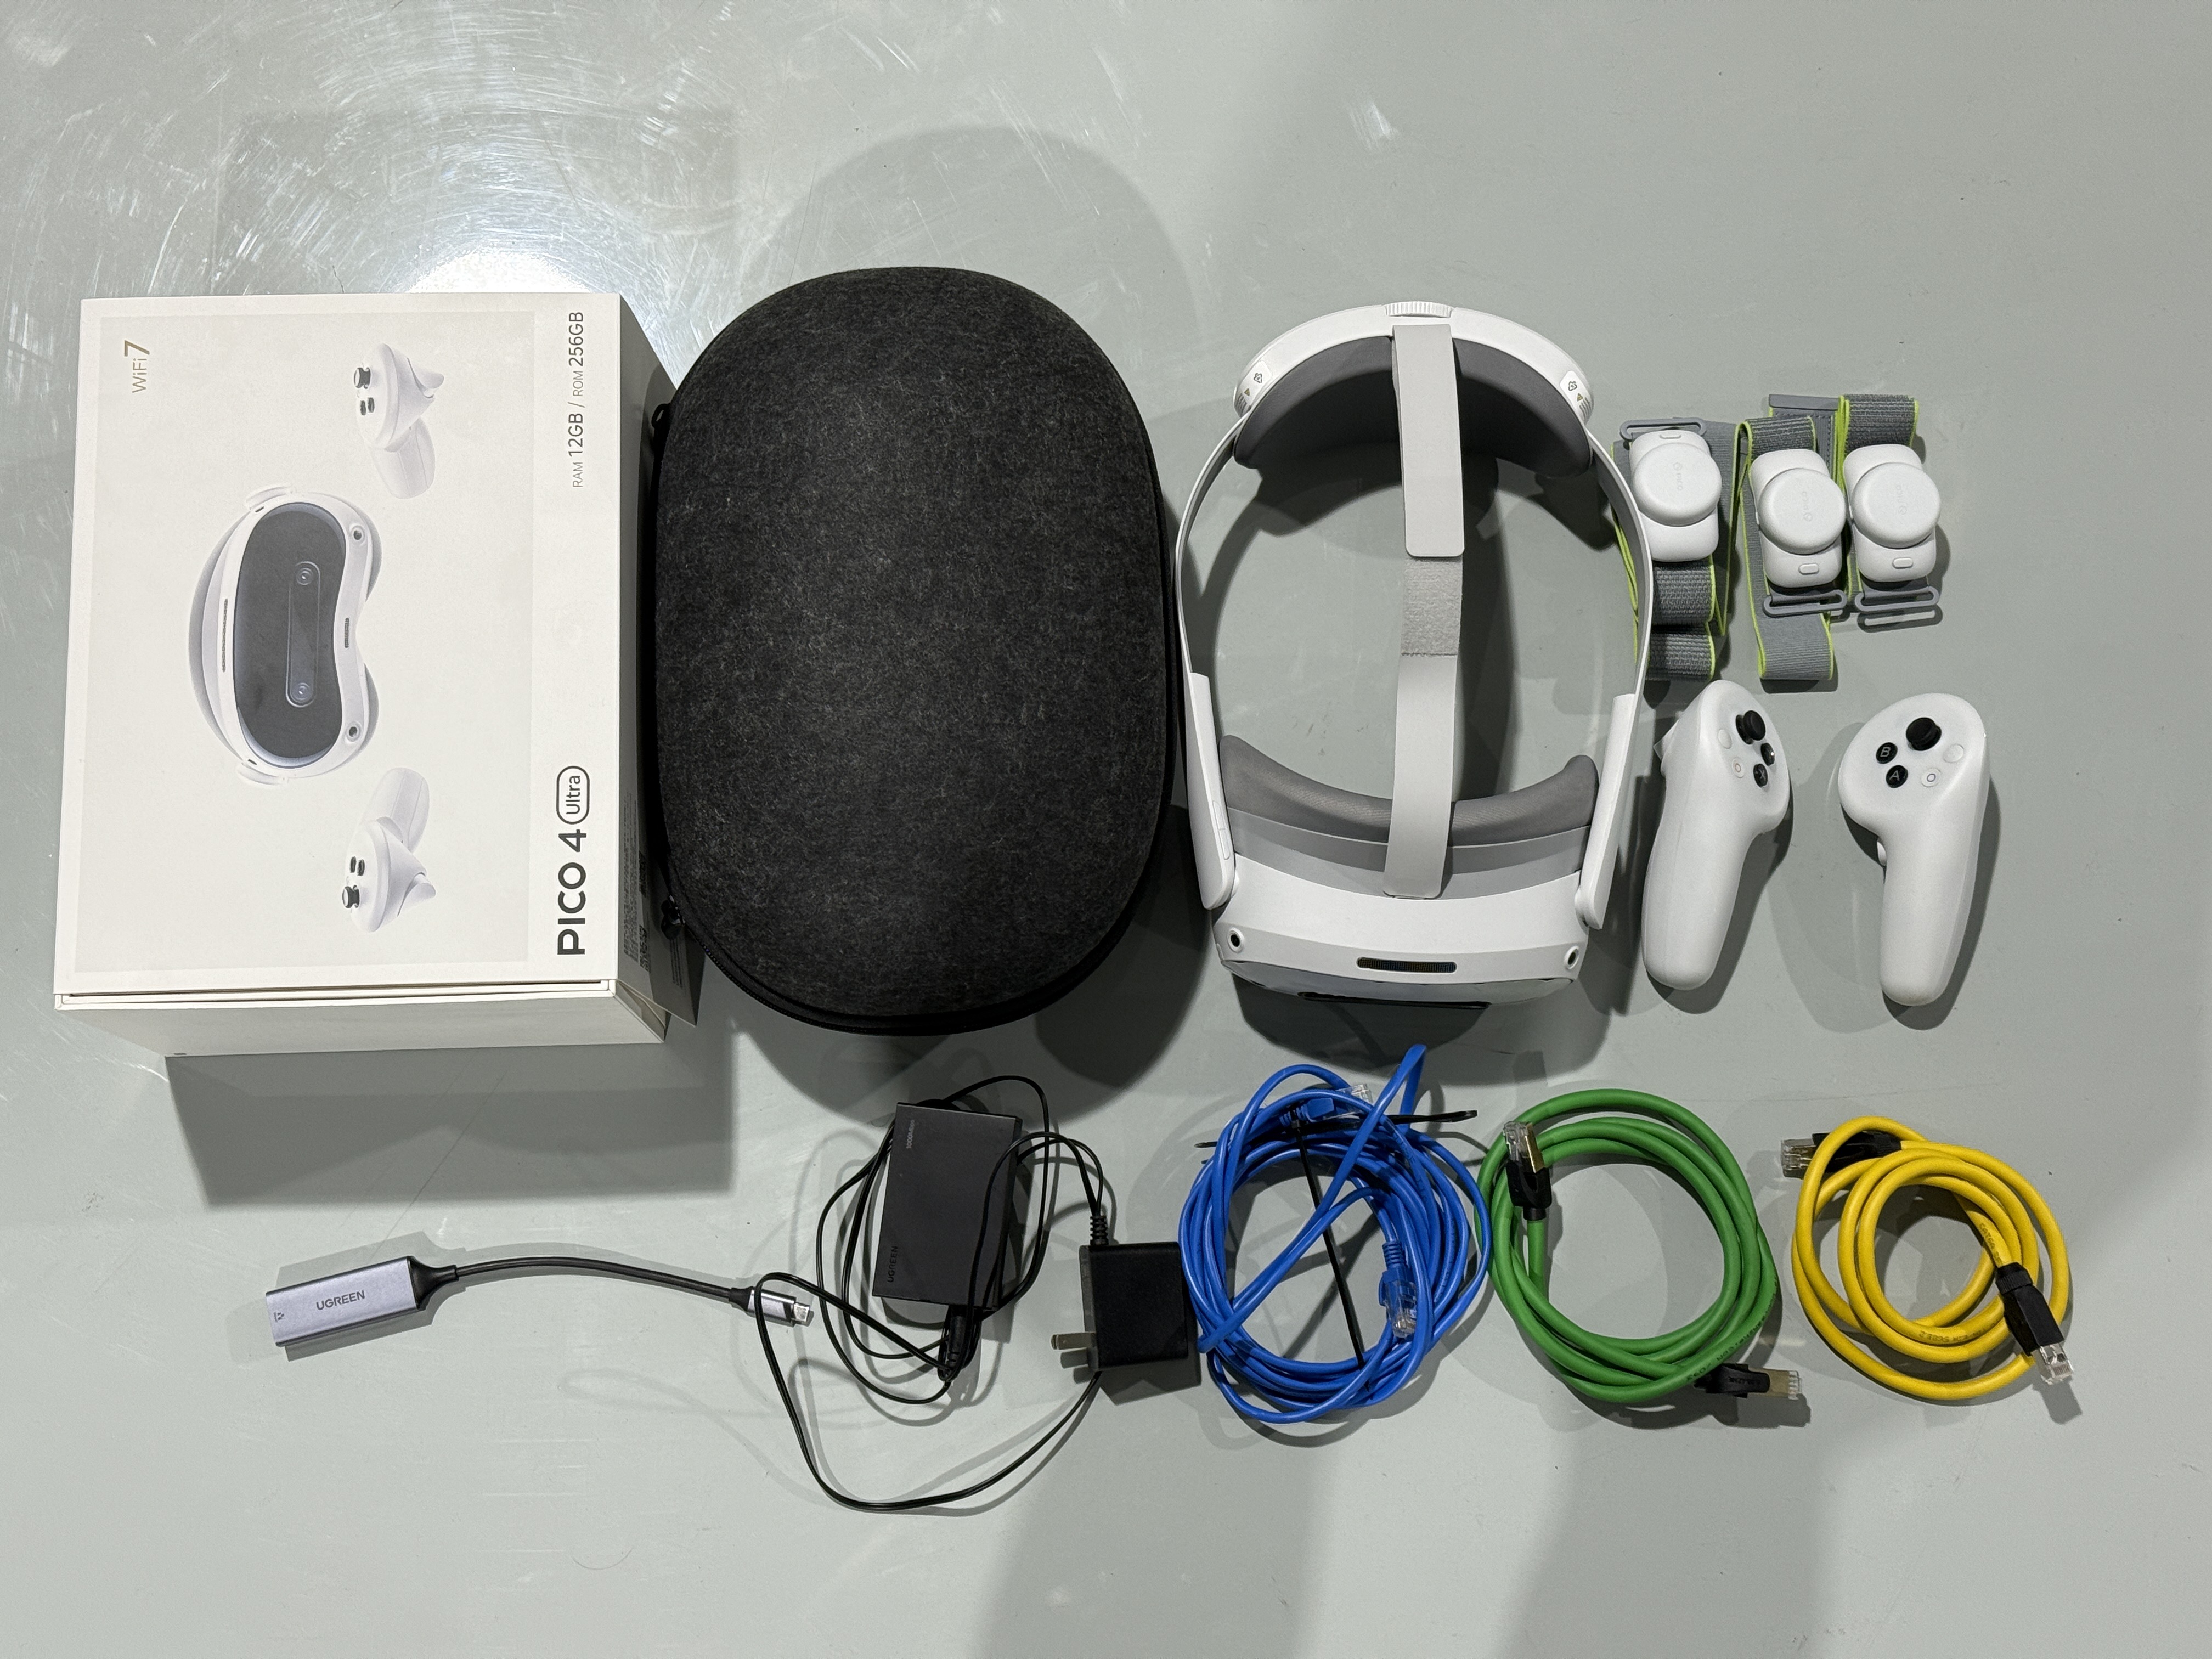
Skye and Luna are robot models that support full-body teleoperation; they are not the name of the teleoperation system. Each delivered robot integrates a Tianzhun 003 control unit, four cameras, and the hardware required for teleoperation. The operator wears a Pico headset, arm units, one waist tracker, and two leg trackers. Skye maps motion to both arms, BODY, and LIFT, while Luna maps motion to both arms, BODY, and legs.
System components
| Component | Description |
|---|---|
| Skye robot | Executes dual-arm, 2-DOF BODY, and 1-DOF LIFT teleoperation; it has no knee joints |
| Luna robot | Executes dual-arm and 6-DOF BODY teleoperation with a knee-style body structure |
| Tianzhun 003 control unit | Runs Apex and ROS 2 control services |
| Four cameras | Provide a four-tile first-person and environment view |
| Pico headset | Displays video and provides head tracking |
| Wearable arm units (left/right) | Capture operator arm motion |
| Waist tracker | Captures torso pose |
| Leg trackers | Two trackers capture lower-body motion for Skye BODY/LIFT or Luna leg mapping |
| Host PC | Runs the classic Apex Teleop interface |
Robot interfaces
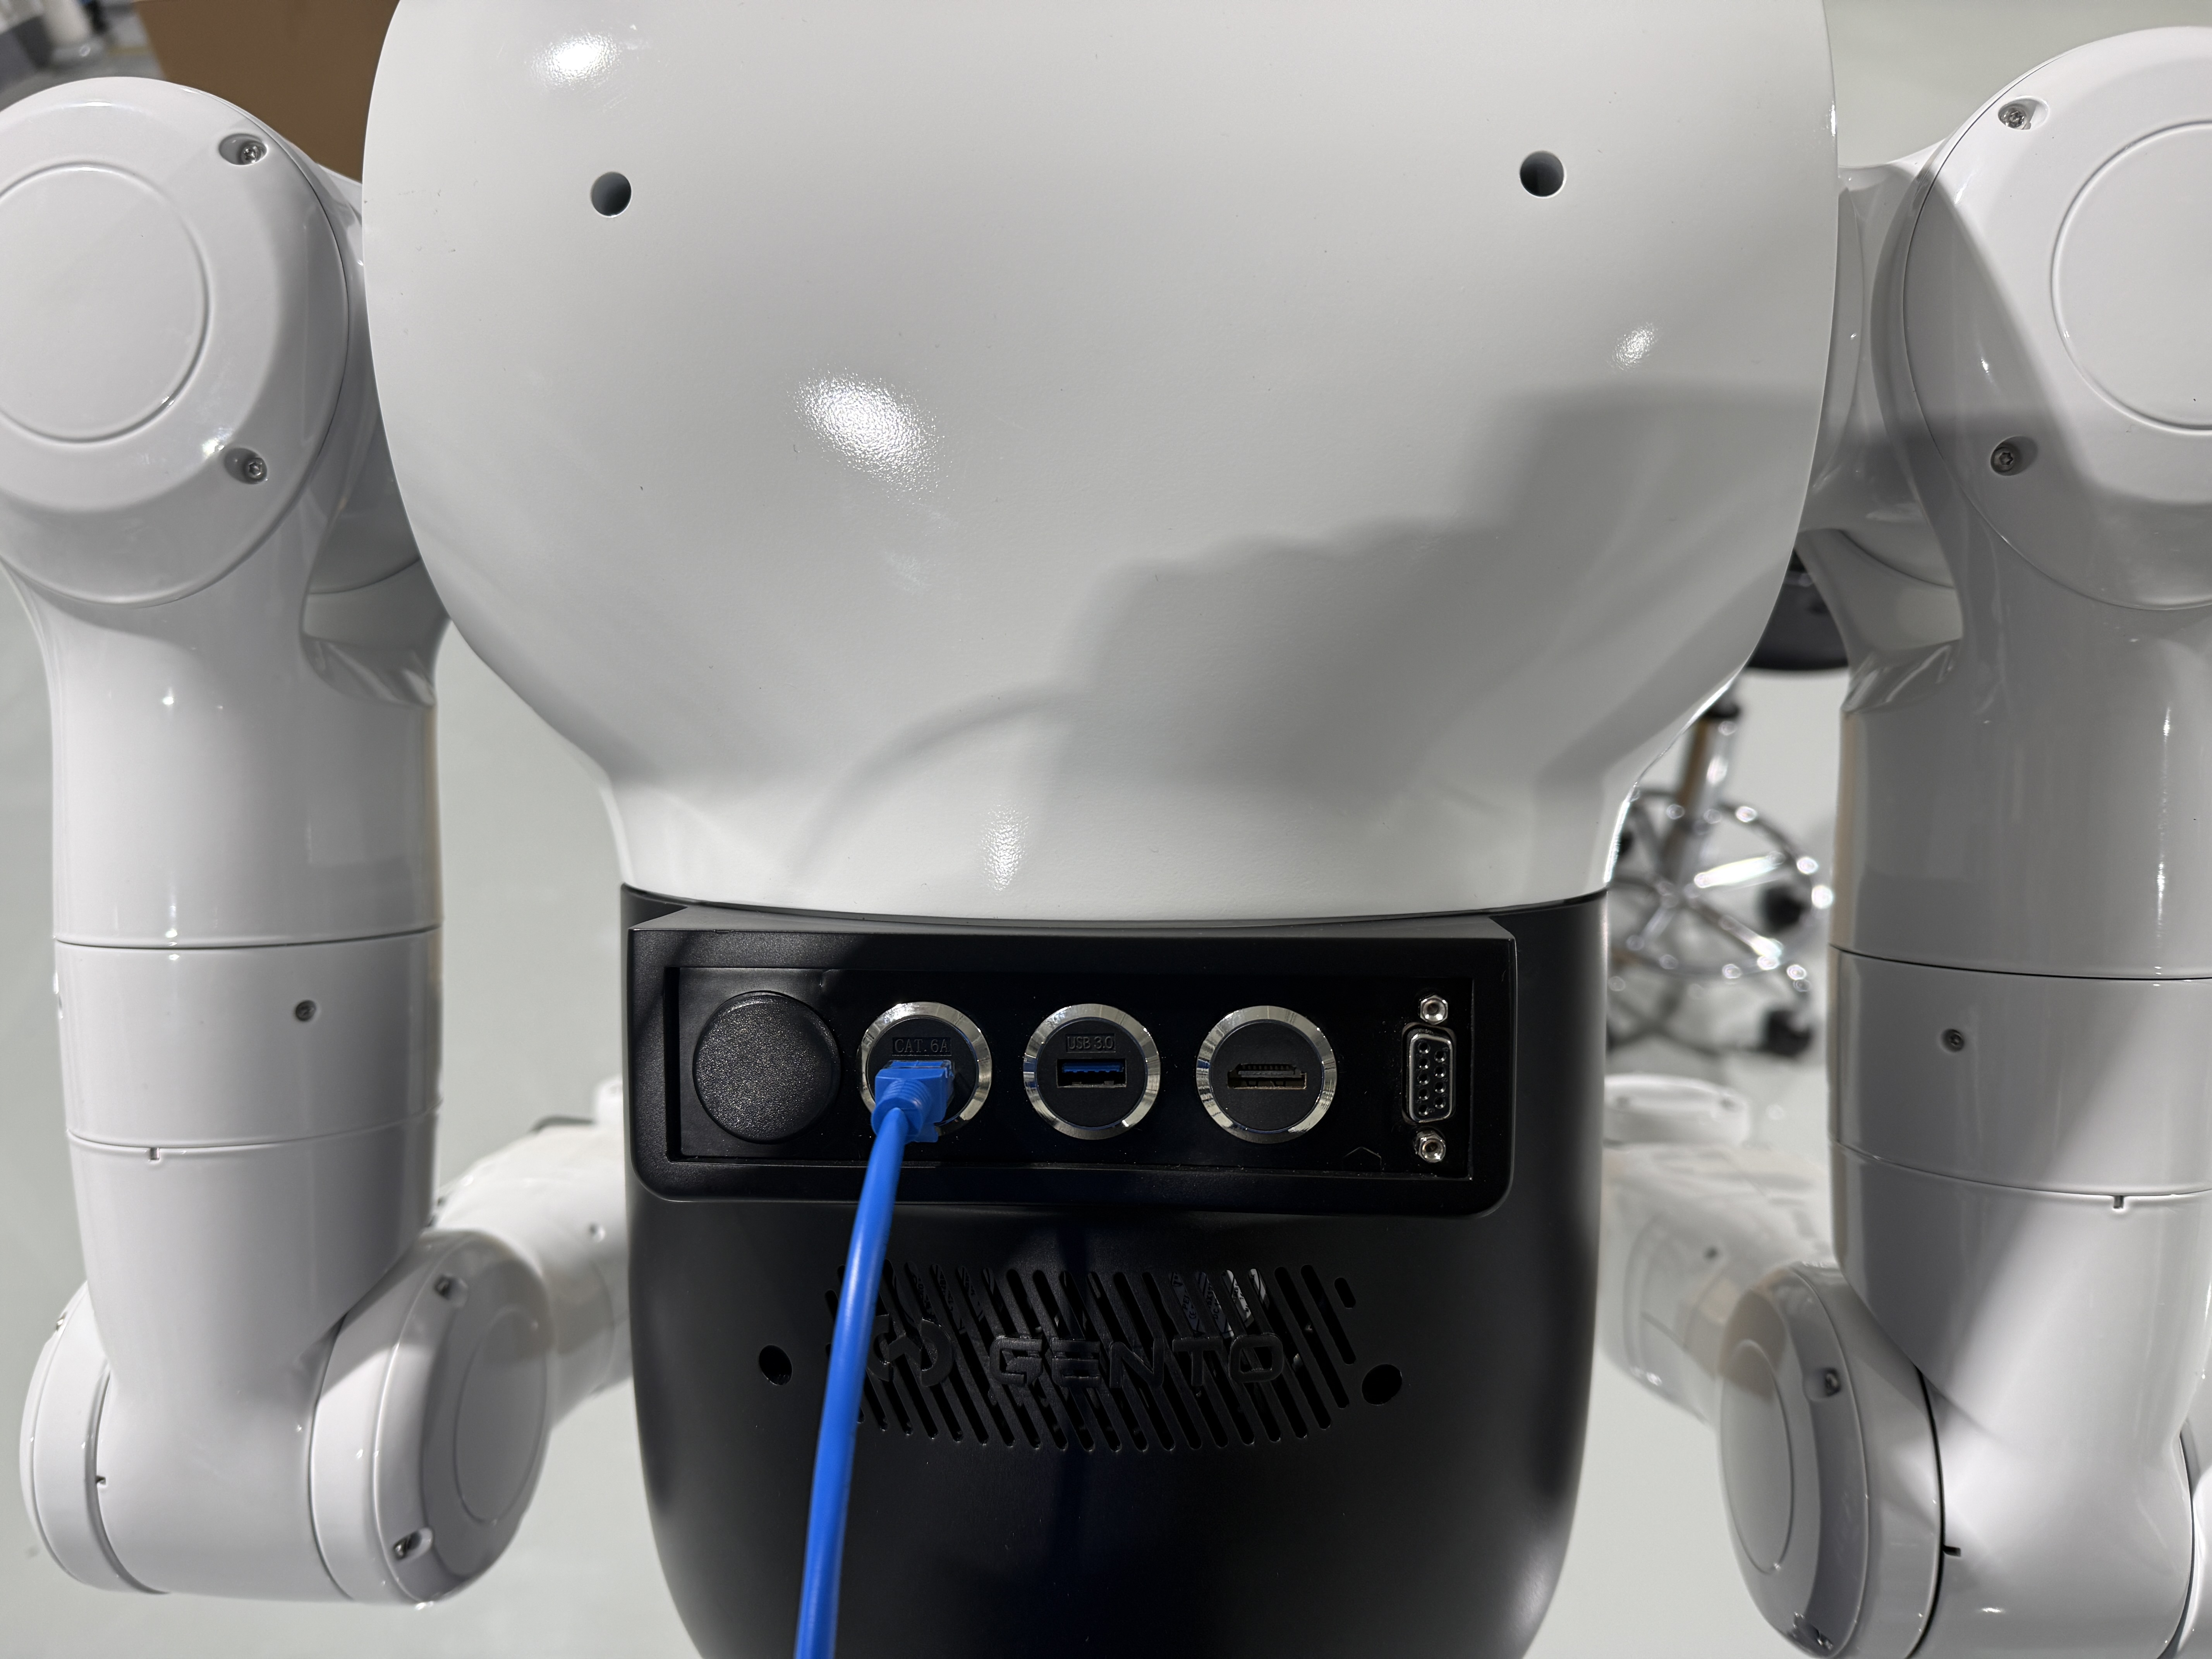
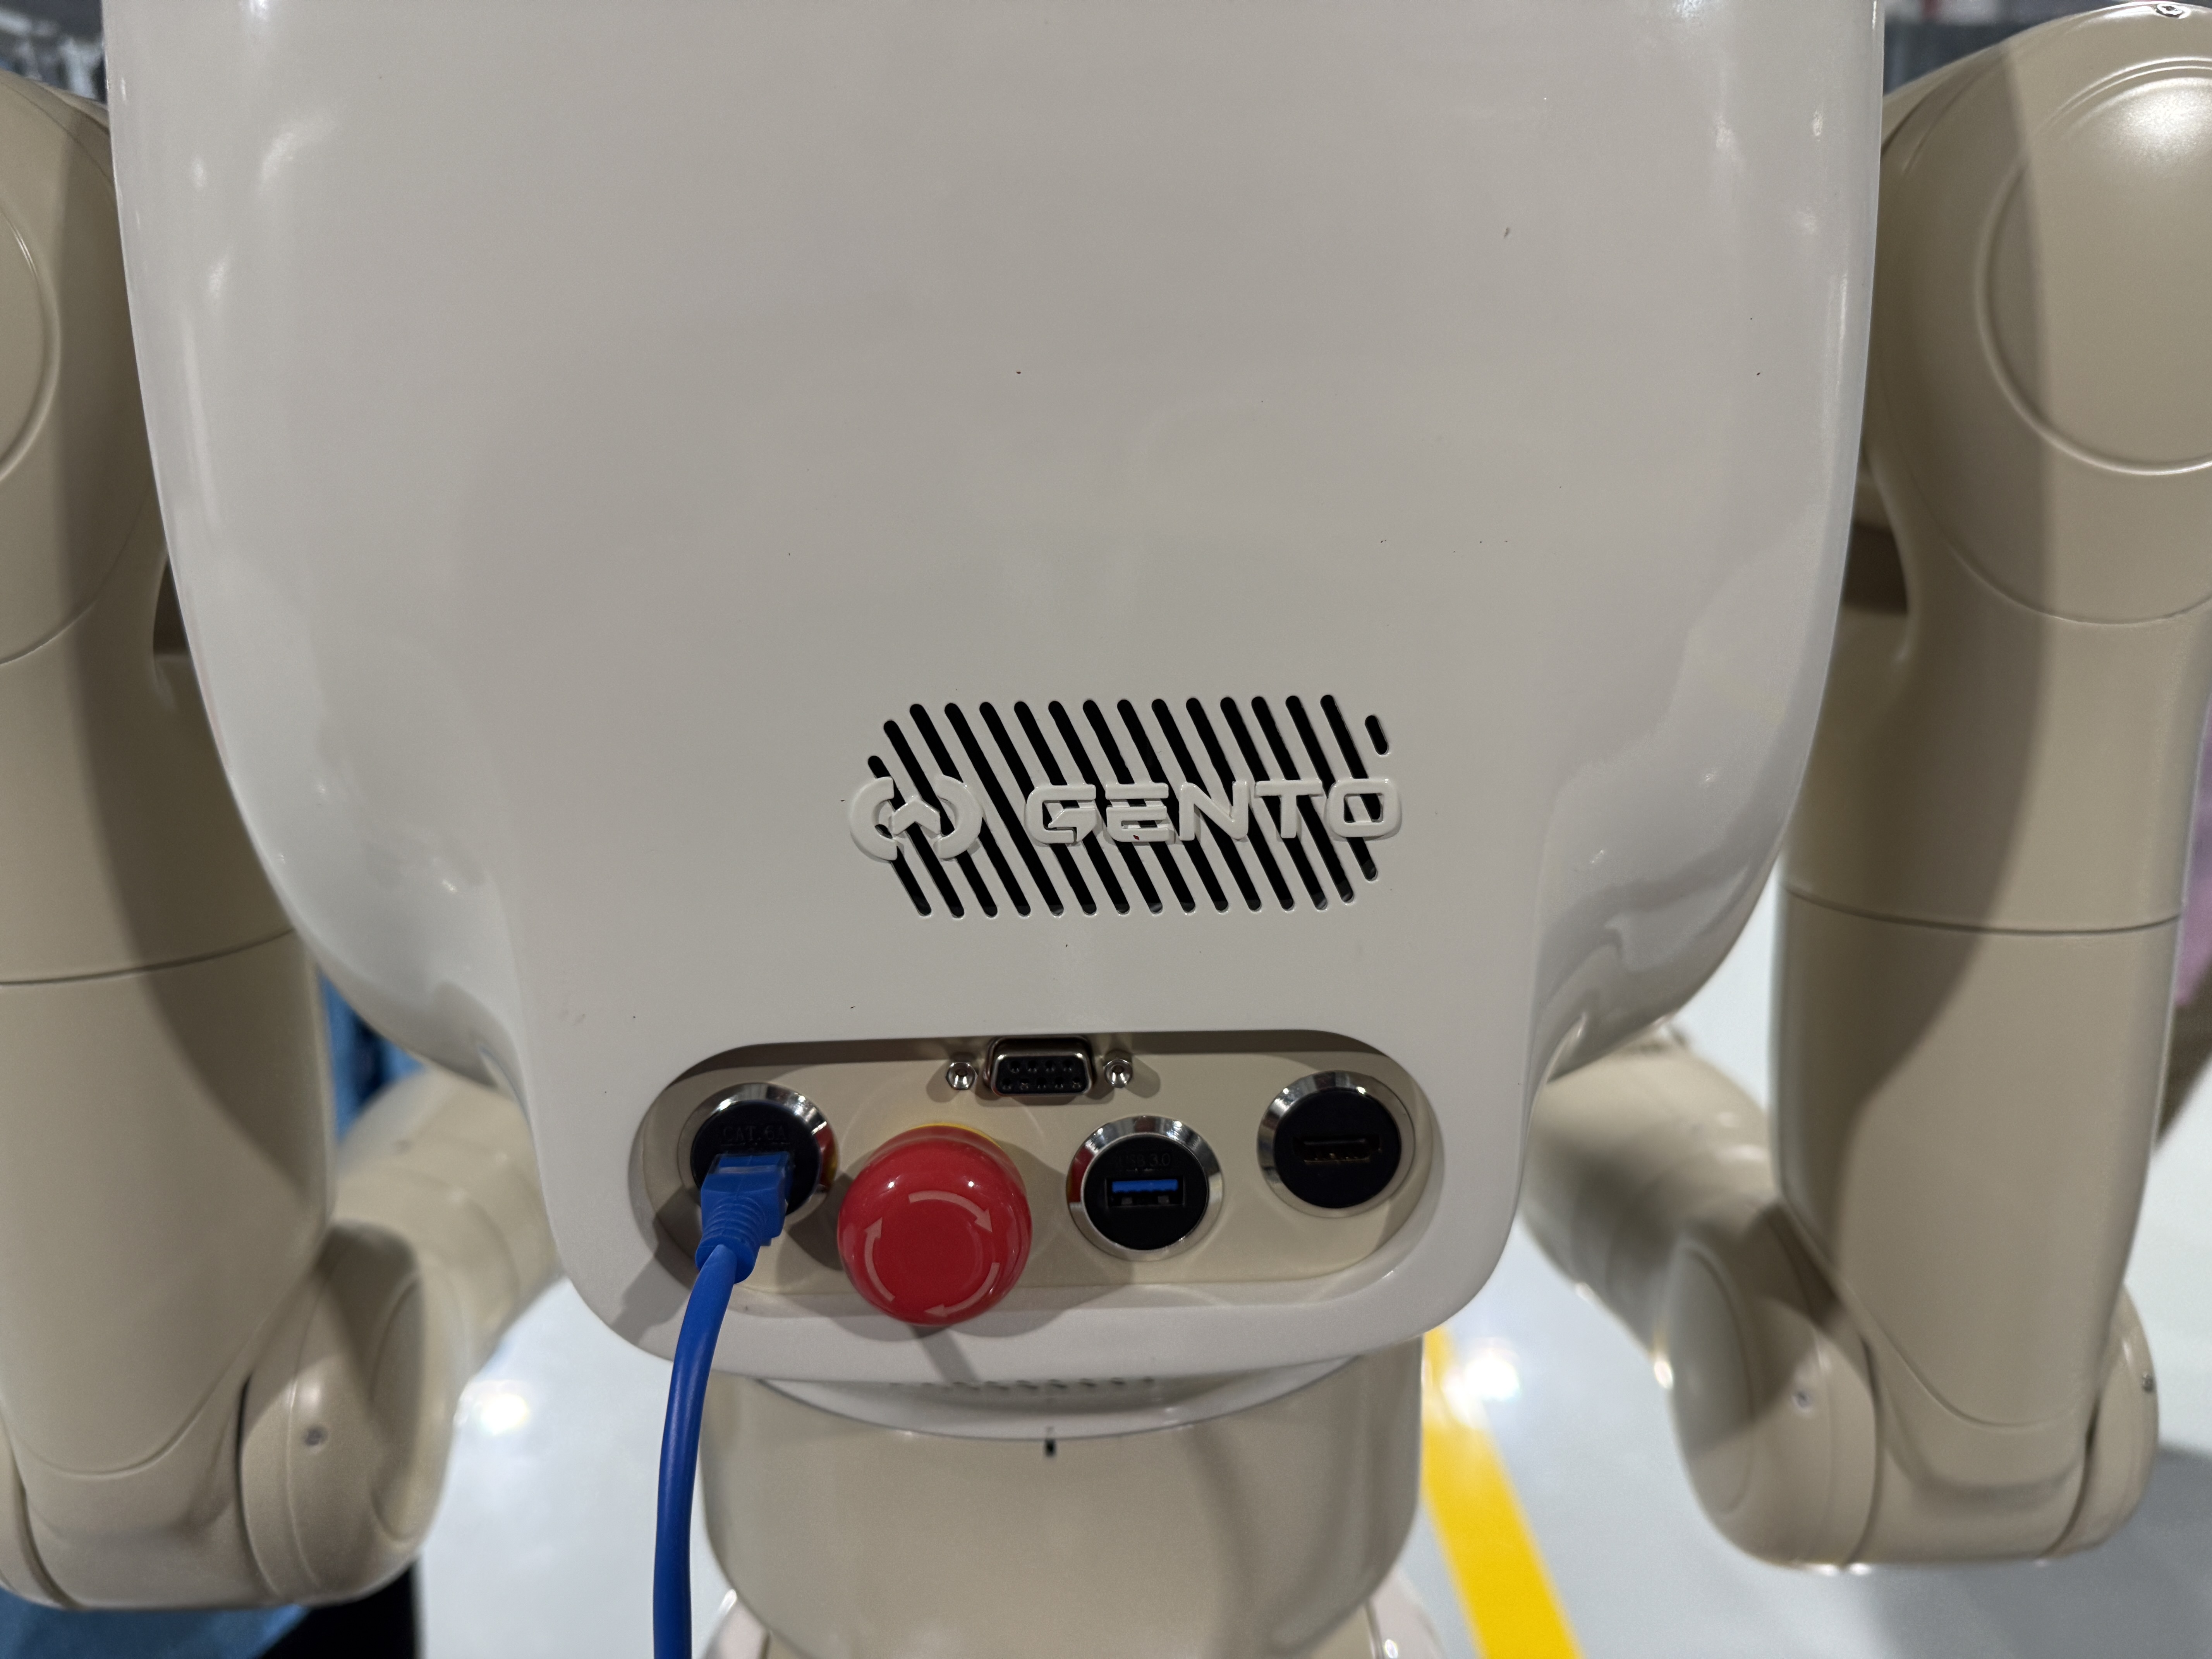
Interface locations differ by model. Follow Hardware Wiring and the labels on the delivered system.
Wearing instructions
- Pico headset: adjust for a clear view and secure fit.
- Wearable arm units: distinguish left and right and keep elbow motion unobstructed.
- Waist tracker: wear it on the back in the specified orientation.
- Leg trackers: install both trackers at the specified positions for full-body tracking. Skye still requires the leg trackers even though the robot has no knee joints.
- Check battery, connection, and tracking state before use.
Standard accessories
| Accessory | Qty | Description |
|---|---|---|
| Pico headset | 1 | Headset used for Skye/Luna full-body teleoperation |
| Wearable arm units (left/right) | 1 each | Capture arm motion |
| Waist tracker | 1 | Captures torso pose |
| Leg trackers | 2 | Capture lower-body motion for Skye BODY/LIFT or Luna leg mapping |
| Ethernet cables | Several | Connect the robot, host PC, network device, and headset adapter |
| Type-C Ethernet adapter | 1 | Connects Pico to the wired LAN |
Software
| Software | Location | Description |
|---|---|---|
| Apex controller software | Tianzhun 003 | Current source-review snapshot is v1.0.6.95g-beta-10-g14cfc0d; use the customer package listed in the delivery manifest |
| Teleop service | Host PC | Use the matching version from the same delivery release; processes teleoperation data |
| Apex frontend | Host PC | Use the matching version from the same delivery release; connects the robot, switches modes, records, plays back, and displays logs |
| Apex Pico client | Pico headset | Network connection, video display, and full-body teleoperation input |
Network
| Item | Description |
|---|---|
| Tianzhun 003 | Default examples use 6.6.7.100; use the actual site address if changed |
| Host PC | Same subnet as Tianzhun 003, with no address conflict |
| Pico headset | Receives another address on the same subnet and connects to the actual Tianzhun 003 IP |
Do not assign the Pico headset the same IP address as Tianzhun 003.
Product differences
- Skye has a 2-DOF BODY and 1-DOF LIFT with no knee joints. Luna has a 6-DOF knee-style body structure.
- Both Skye and Luna use one waist tracker and two leg trackers for full-body mapping. Marvin Pro primarily supports dual-arm teleoperation.
- Skye/Luna uses Pico waist and leg tracking and does not use Meta Quest as the standard full-body headset.
- Skye/Luna currently uses the classic Apex Teleop interface.